Robotics · 2026–present
Robots
Robot manipulation, visual navigation, and VR teleoperation.
Galaxea A1
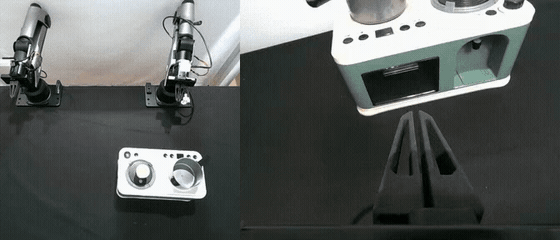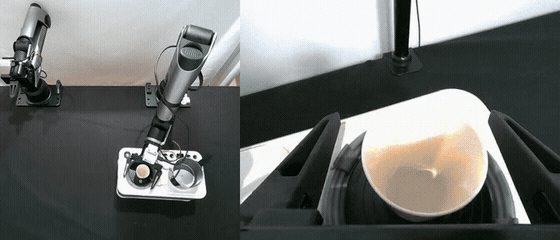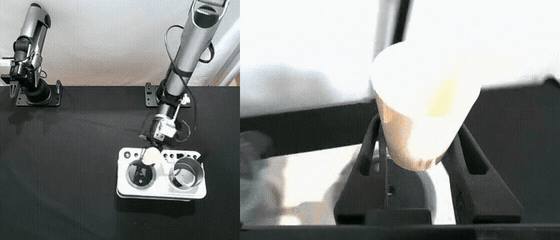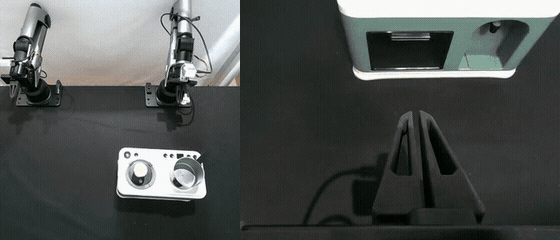
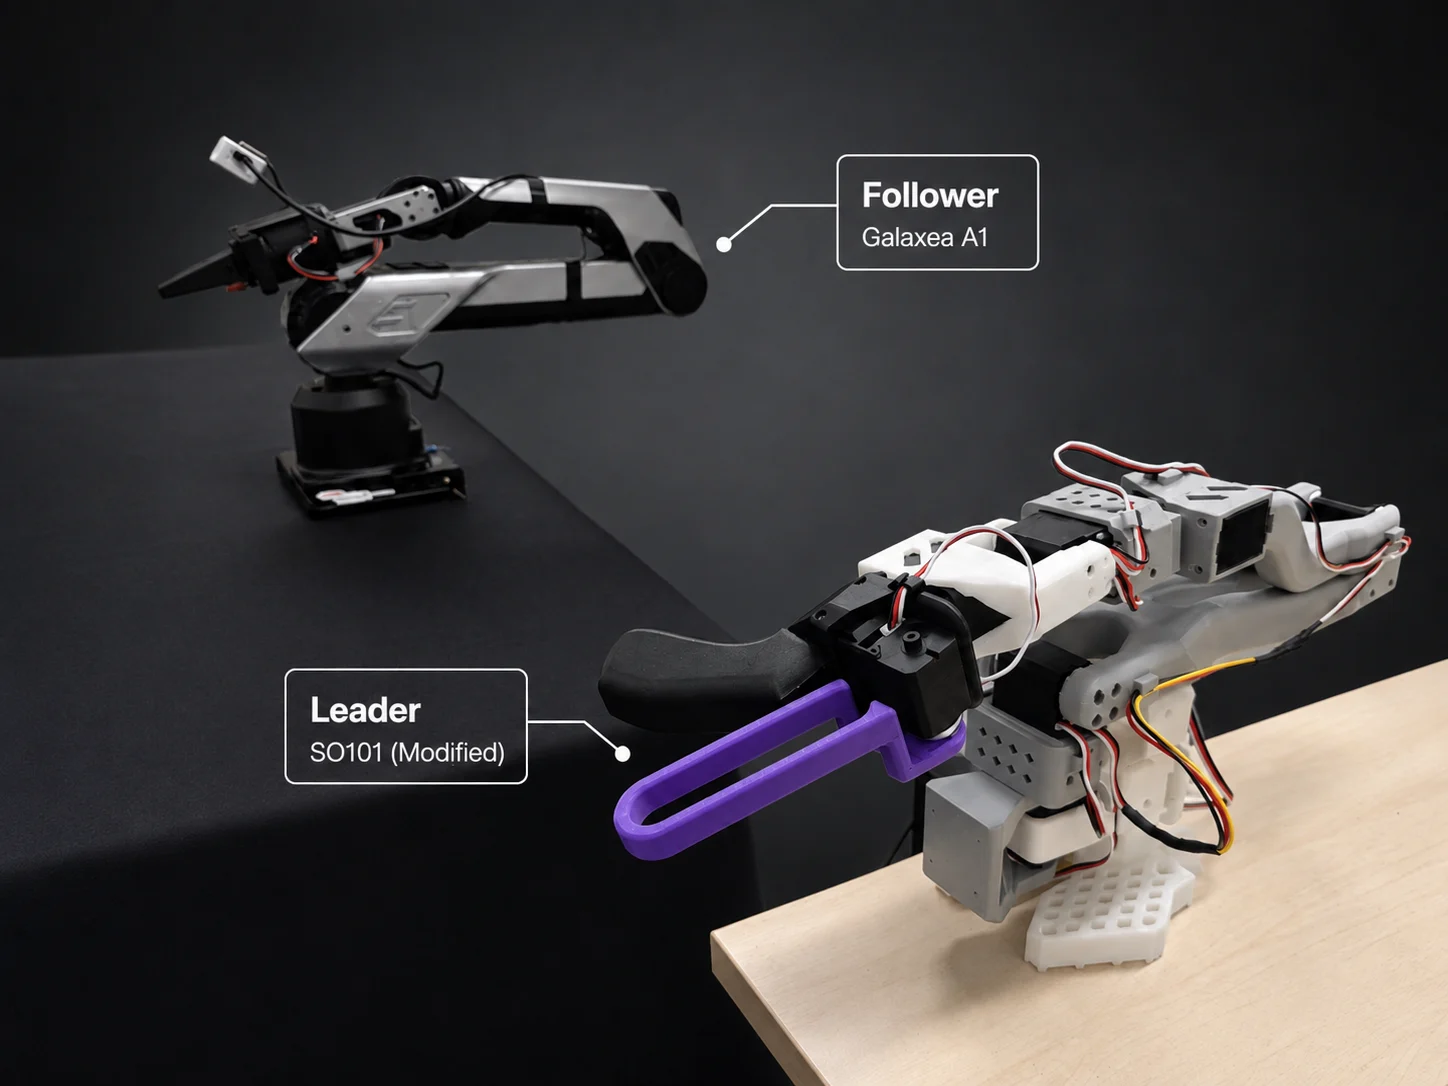
I built the teleoperation and LeRobot tools for this setup when the official software did not yet cover my experiments. I used it to collect demonstrations and deploy LingBot-VA and π0.5.
Unitree Go2
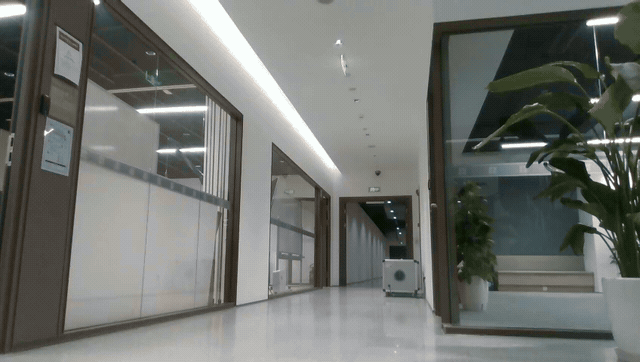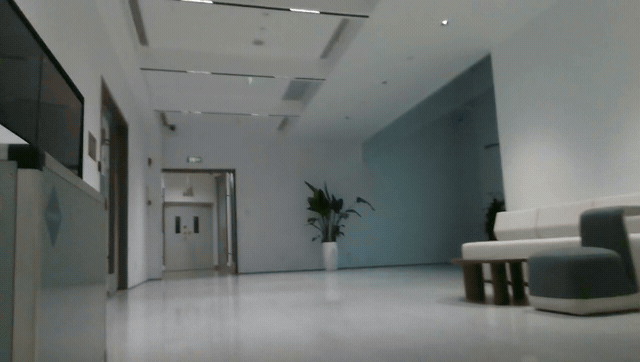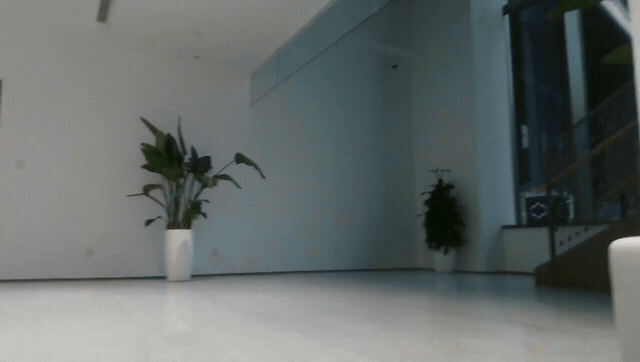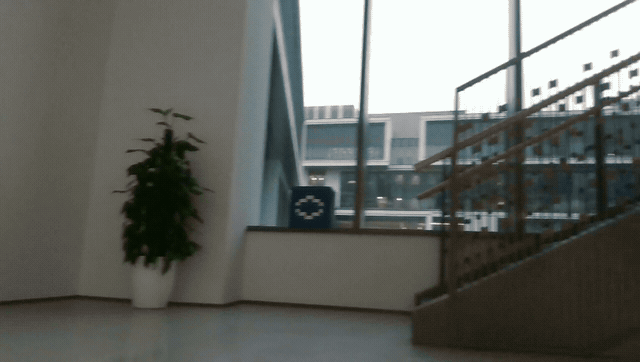
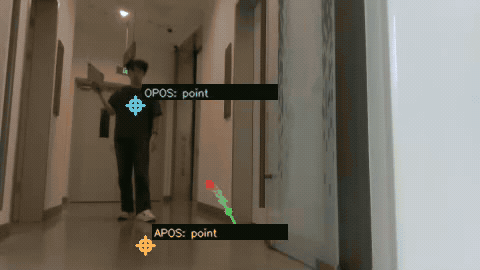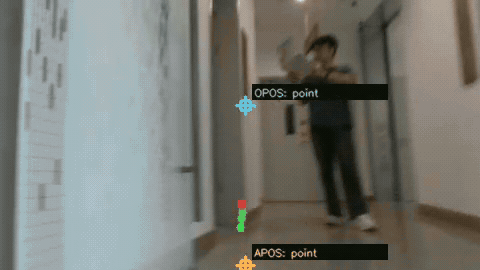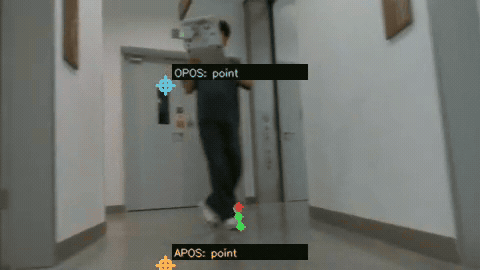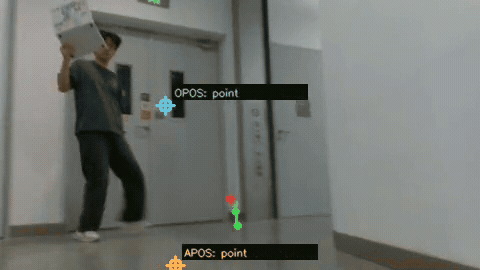
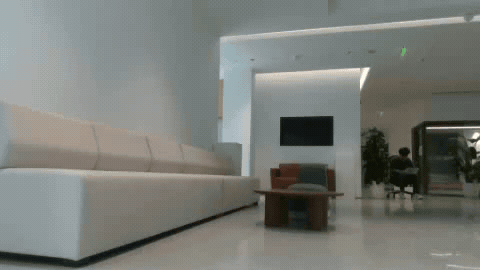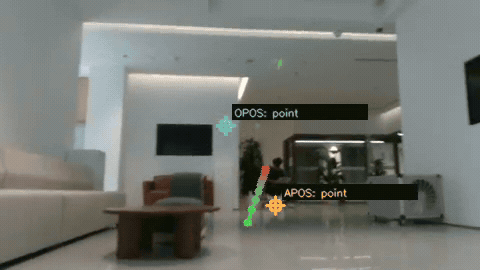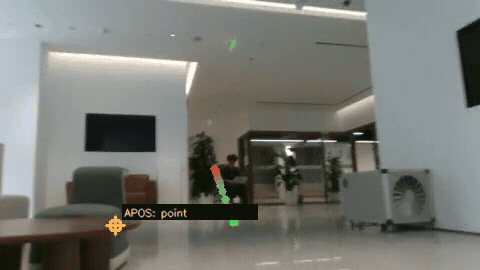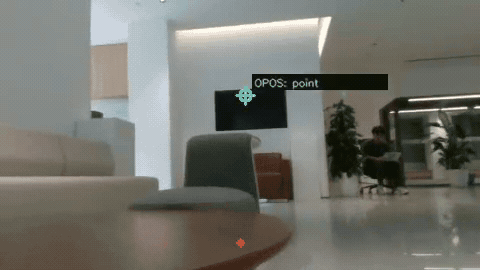
I deployed NavDP and LightNav on the Go2, with asynchronous inference split between its onboard computer and a separate GPU machine. The onboard side handles observations and motion control; the GPU runs the policy.
Unitree G1
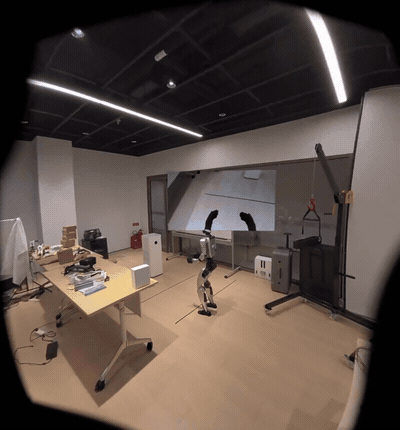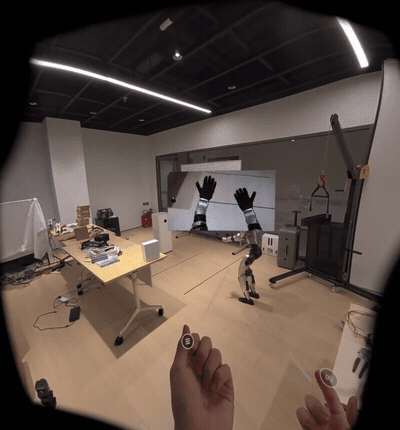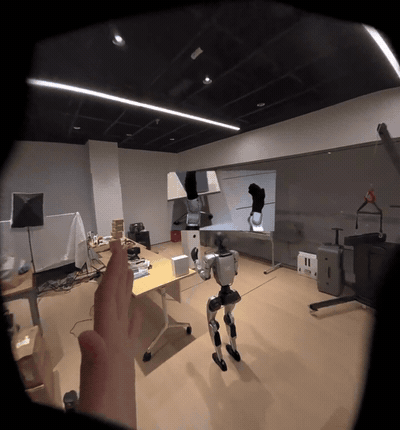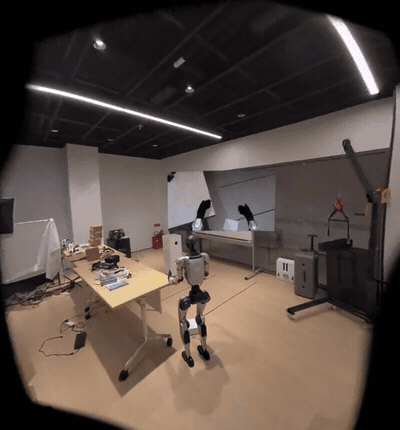
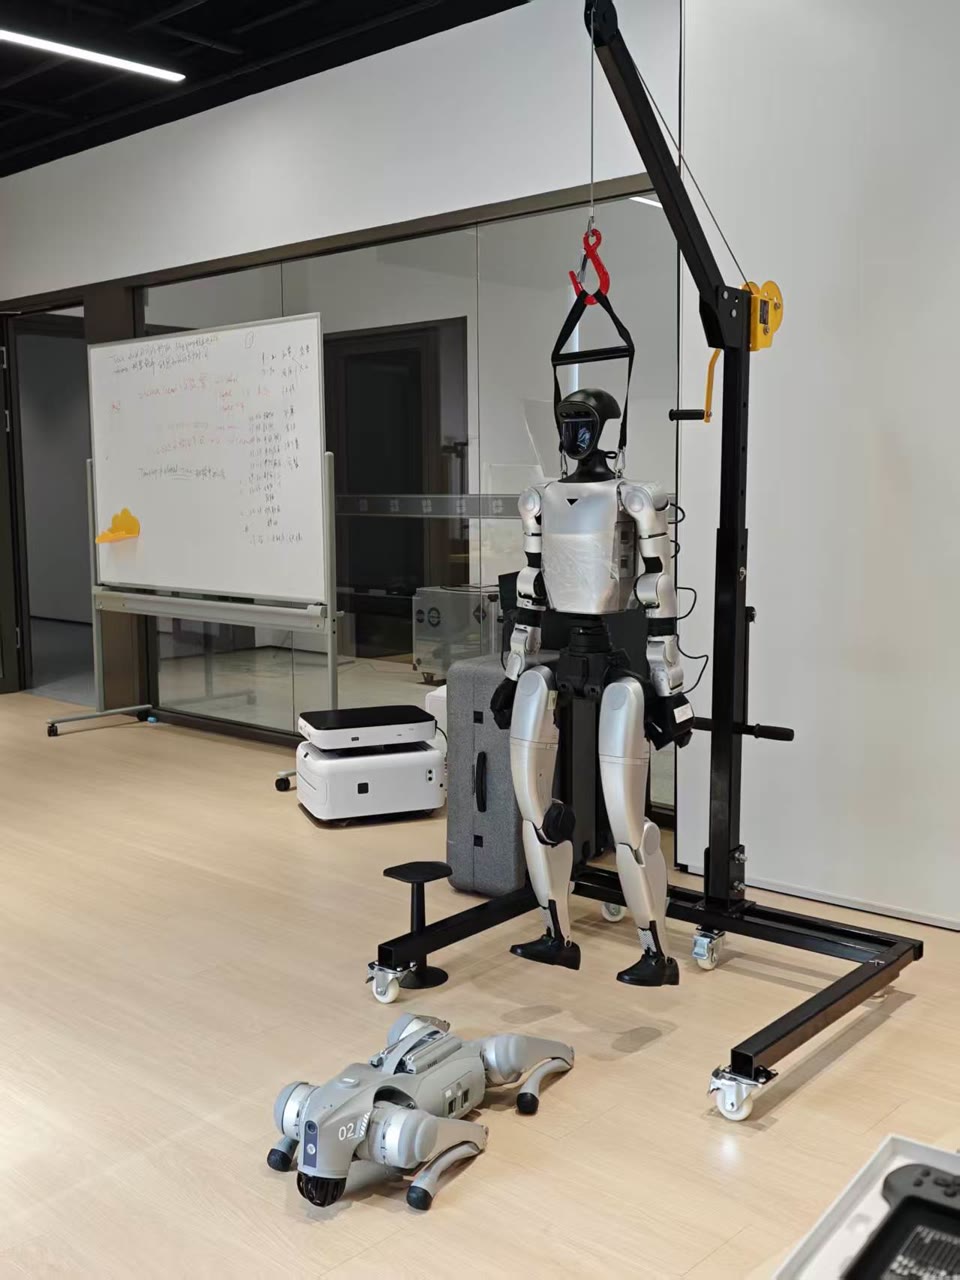
VR teleoperation on the G1 using Unitree’s xr_teleoperate. The headset recording shows the robot responding to the operator’s arm movements.
OpenArm
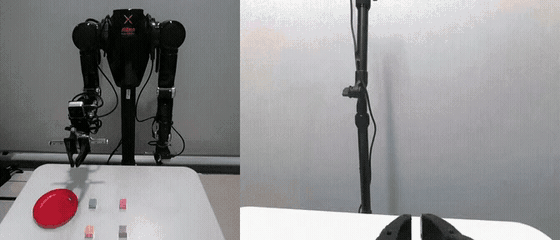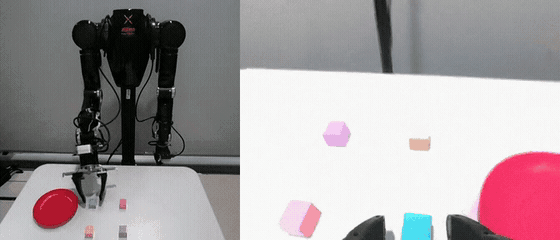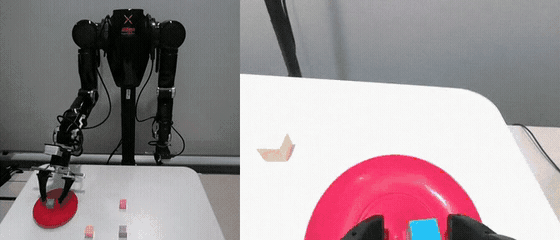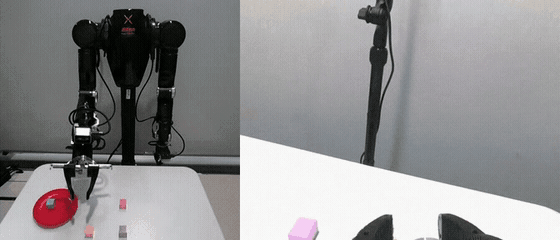
I used the official tools to deploy OpenArm, worked on data collection, and fine-tuned LingBot-VA for the right arm.