Competition robotics · 2025–present
NYU Shanghai RoboMaster
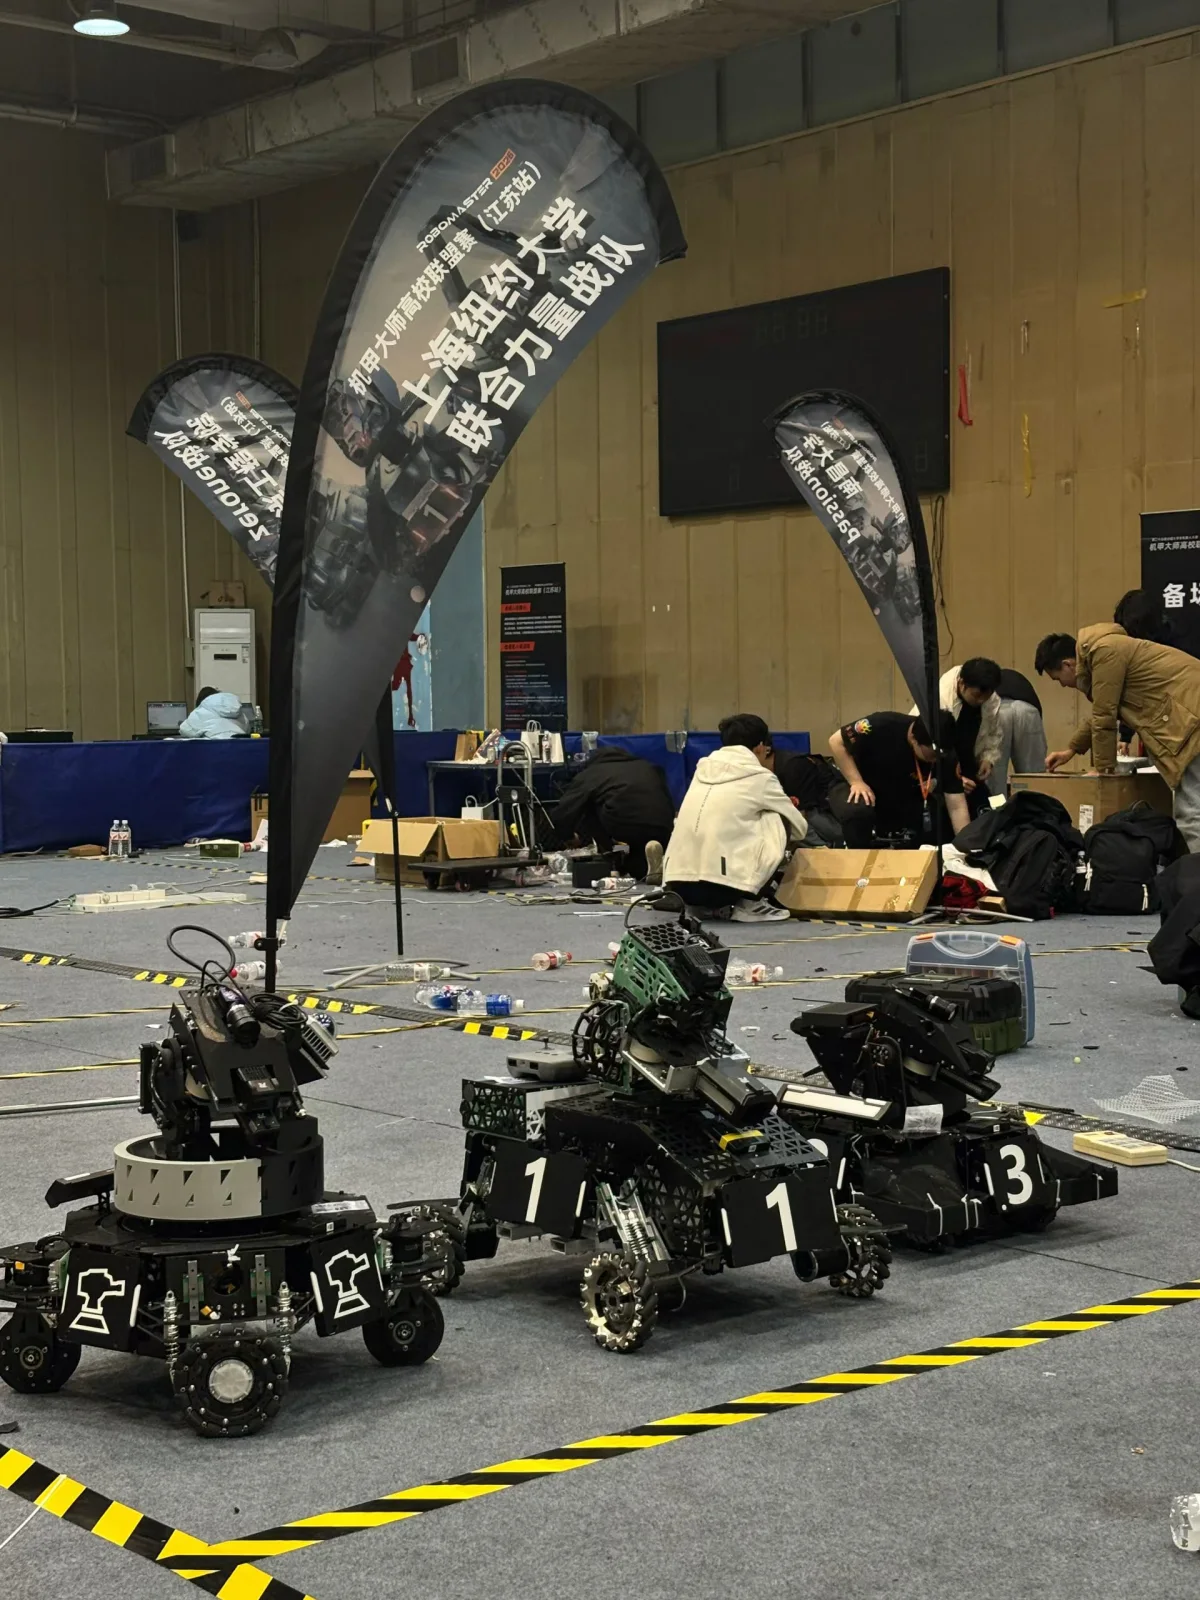
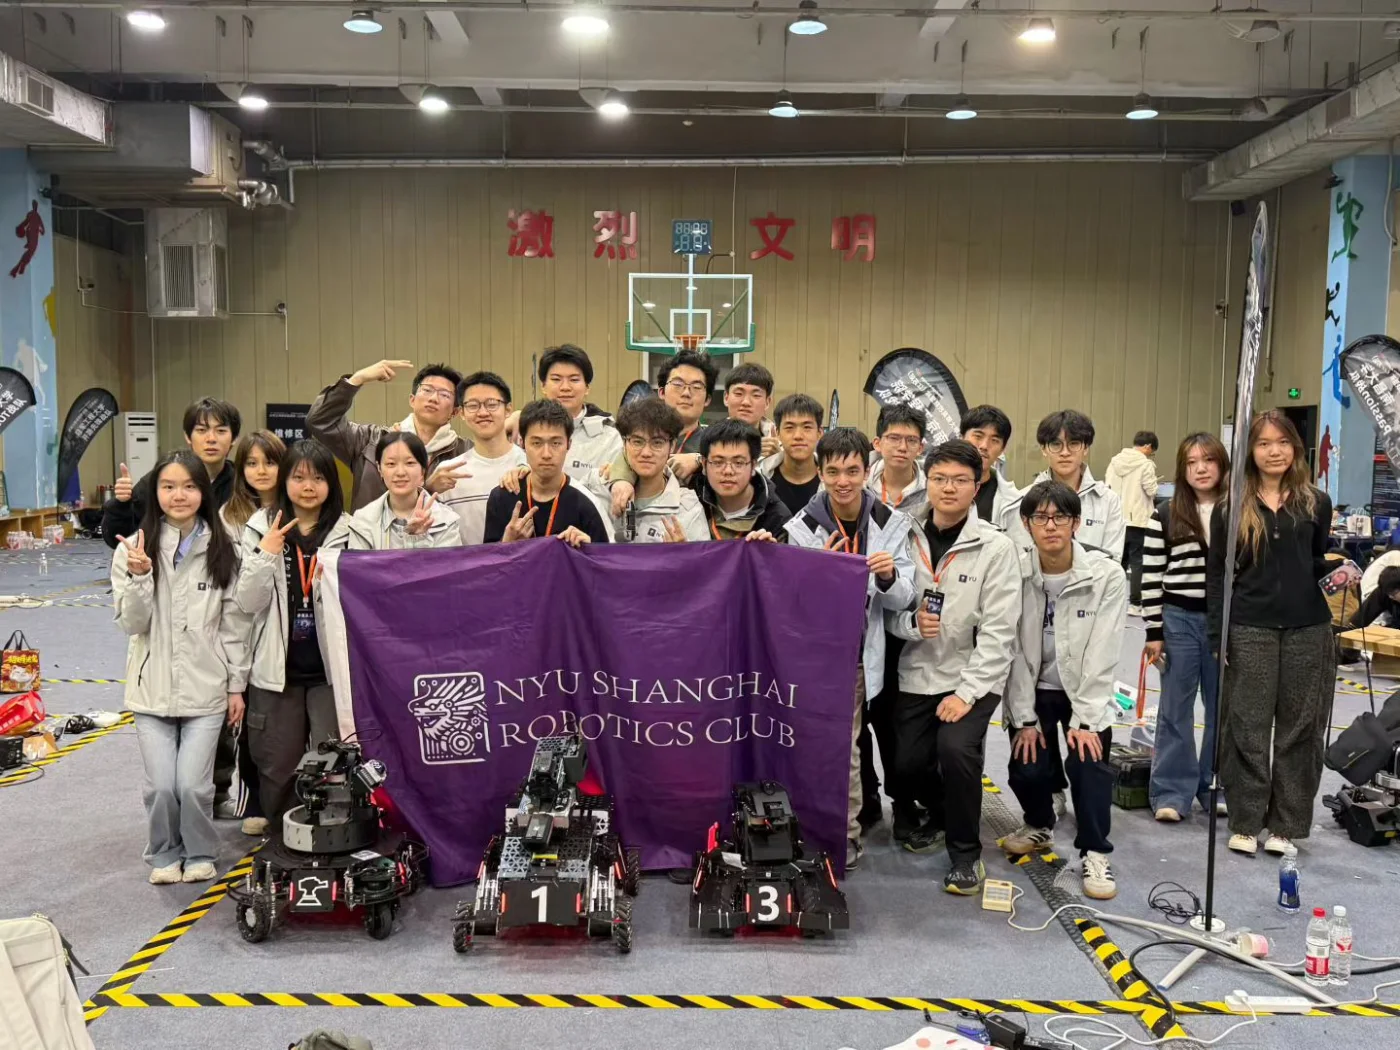
I co-founded NYU Shanghai’s RoboMaster team and served as president of the Robotics Club in 2025–2026. I mainly work on electrical and embedded control, with some vision integration, team operations, and media work.
Electrical and embedded control
2025–present
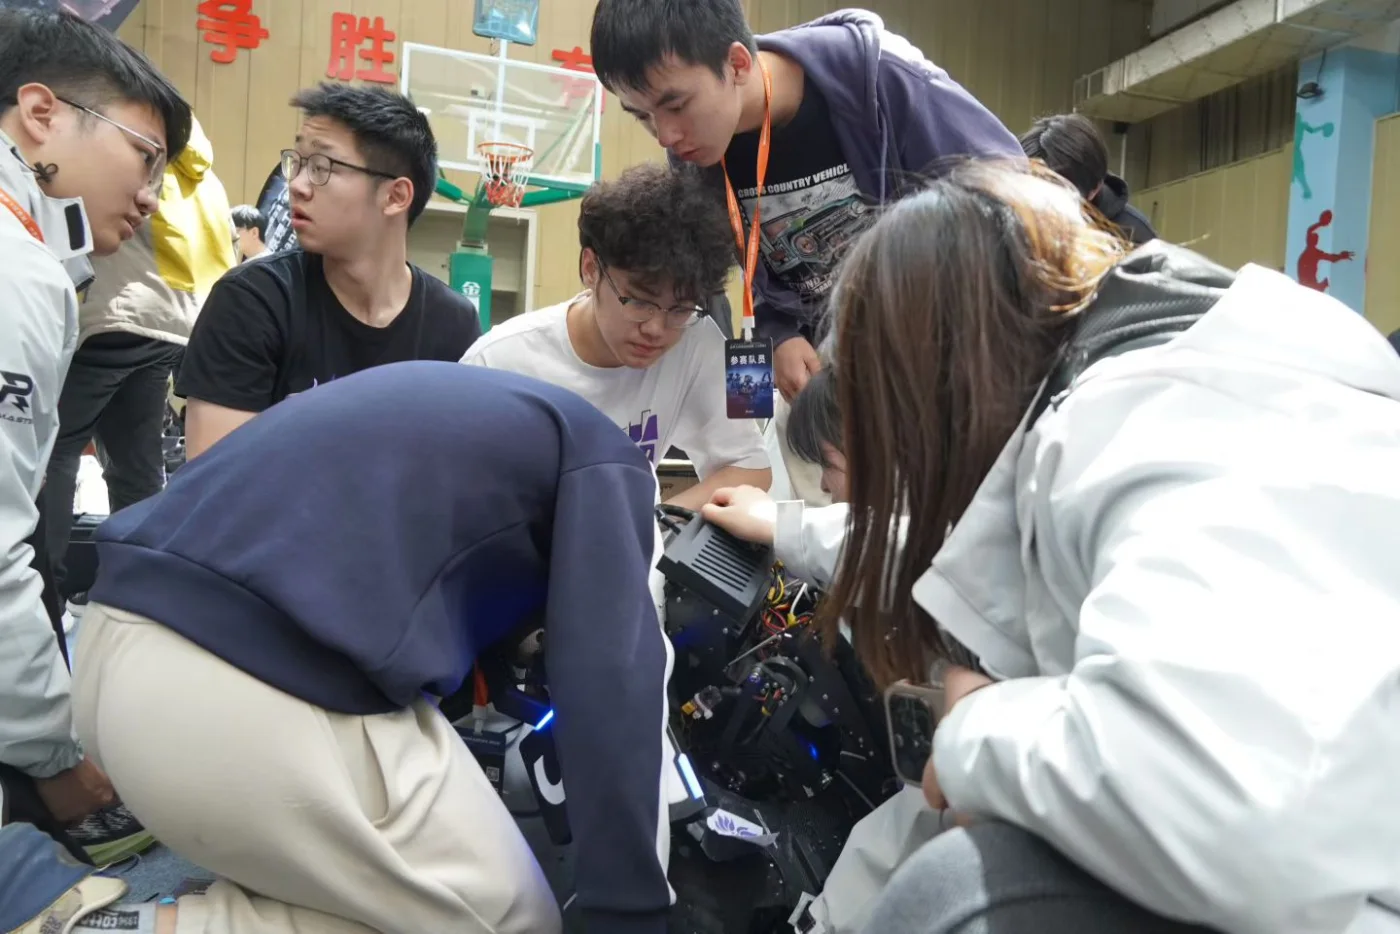
I write the STM32F407 and FreeRTOS firmware that turns operator, referee-system, and vision inputs into chassis, gimbal, and shooter control. CAN connects the motors and sensors. I also maintain robot configurations, power control, vision telemetry, and the build, flashing, and RTT tools we use in the lab and at competitions.
Control inputs
A pub-sub firmware stack adapted for each robot
Real-time control
The same tools travel with us from the lab to the pit
Vision and navigation
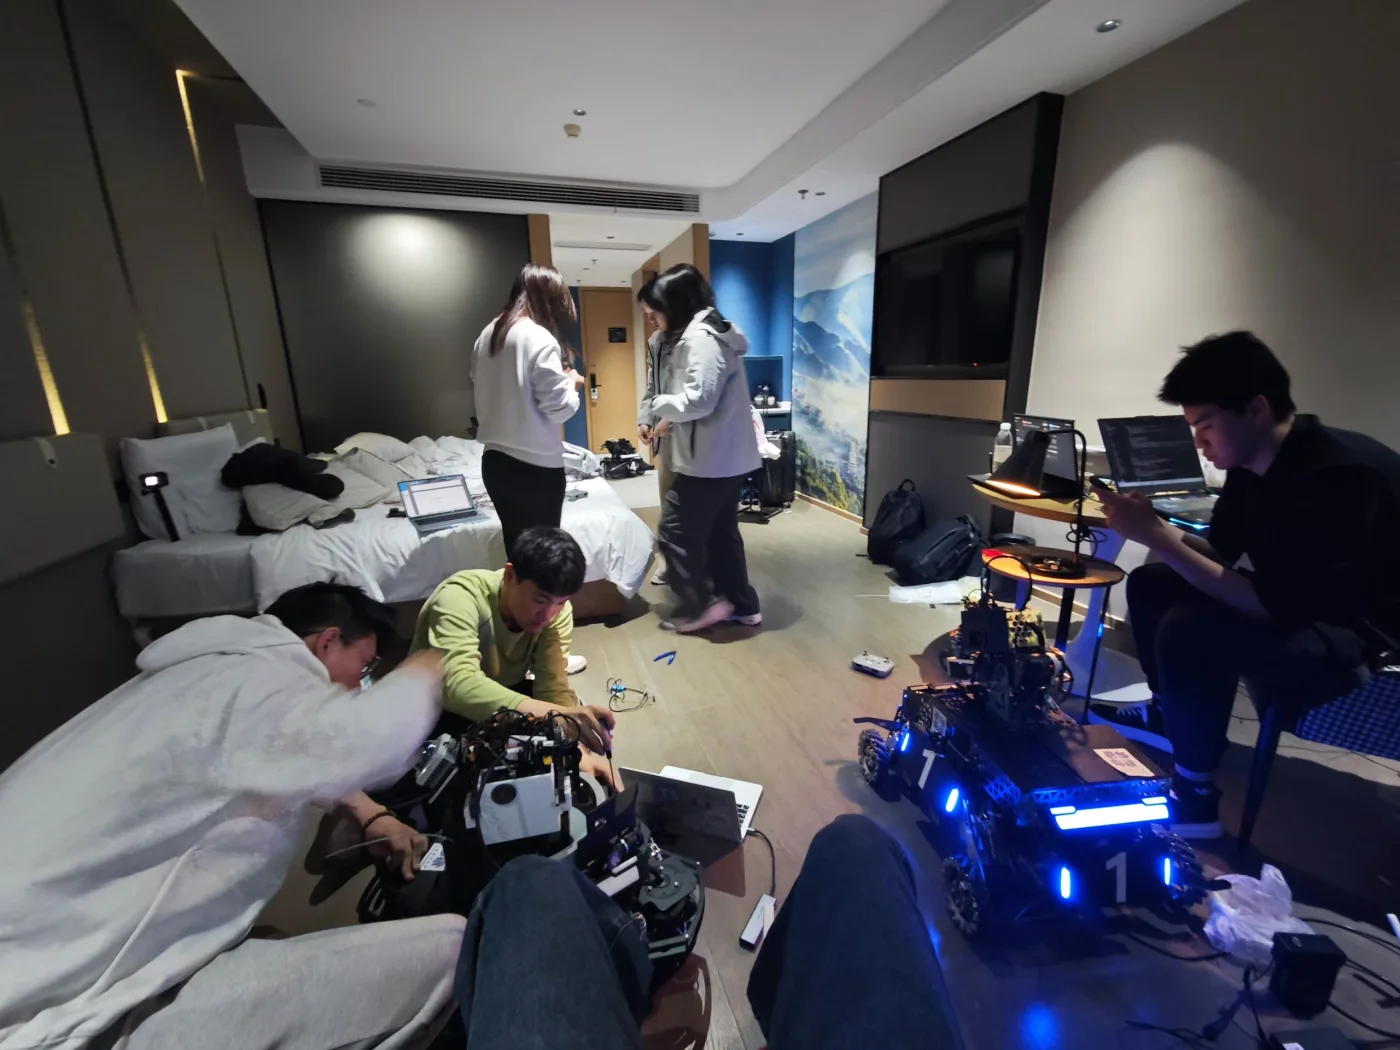
I connect the vision computer to the control board, sending tracking results, gimbal targets, and firing commands over serial. I have also worked on perception and navigation with the autonomy group.
Jiangyin competition
2026
At a RoboMaster university alliance event in Jiangyin, I was primarily responsible for our infantry robot. The team received second prize.
Robotics Club president
2025–2026
As president of the NYU Shanghai Robotics Club, I coordinated club and team operations and worked on recruitment, outreach, and media.